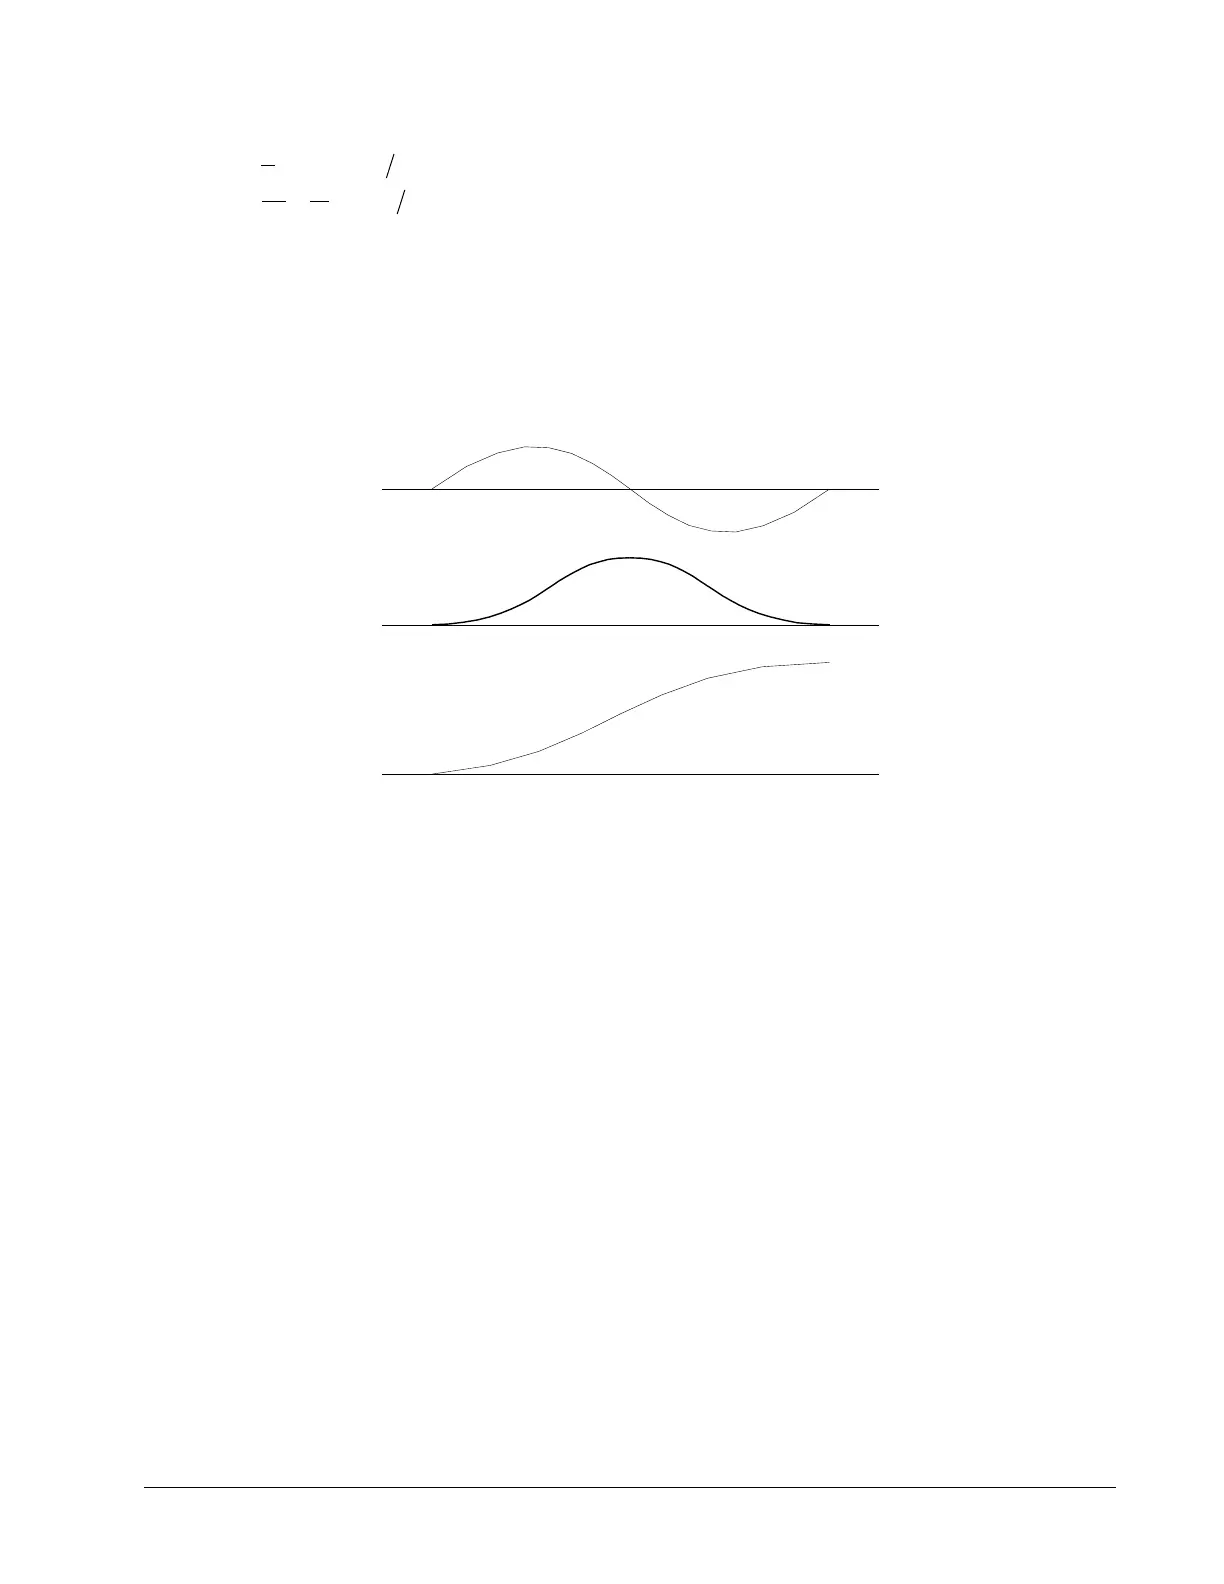
Note: ω is the angular velocity; X is the position; and T is the variable, time, in milliseconds.
In the given example, A=6000 and B=120, the position and velocity profiles are:
X = 50T - (6000/2π) sin (2π T/120)
Note that the velocity, ω, in count/ms, is
ω = 50 [1 - cos 2π T/120]
Figure 6.19: Velocity Profile with Sinusoidal Acceleration
The DMC-40x0 can compute trigonometric functions. However, the argument must be expressed in degrees. Using
our example, the equation for X is written as:
X = 50T - 955 sin 3T
A complete program to generate the contour movement in this example is given below. To generate an array, we
compute the position value at intervals of 8 ms. This is stored at the array POS. Then, the difference between the
positions is computed and is stored in the array DIF. Finally the motors are run in the contour mode.
Contour Mode Example
INSTRUCTION INTERPRETATION
#POINTS Program defines X points
DM POS[16] Allocate memory
DM DIF[15]
C=0 Set initial conditions, C is index
T=0 T is time in ms
#A
V1=50*T
V2=3*T Argument in degrees
V3=-955*@SIN[V2]+V1 Compute position
V4=@INT[V3] Integer value of V3
POS[C]=V4 Store in array POS
T=T+8
C=C+1
JP #A,C<16
DMC-40x0 User Manual Chapter 6 Programming Motion • 112


 To Next Page