It requires more time to carry out the control action than the P controller .
PI controller
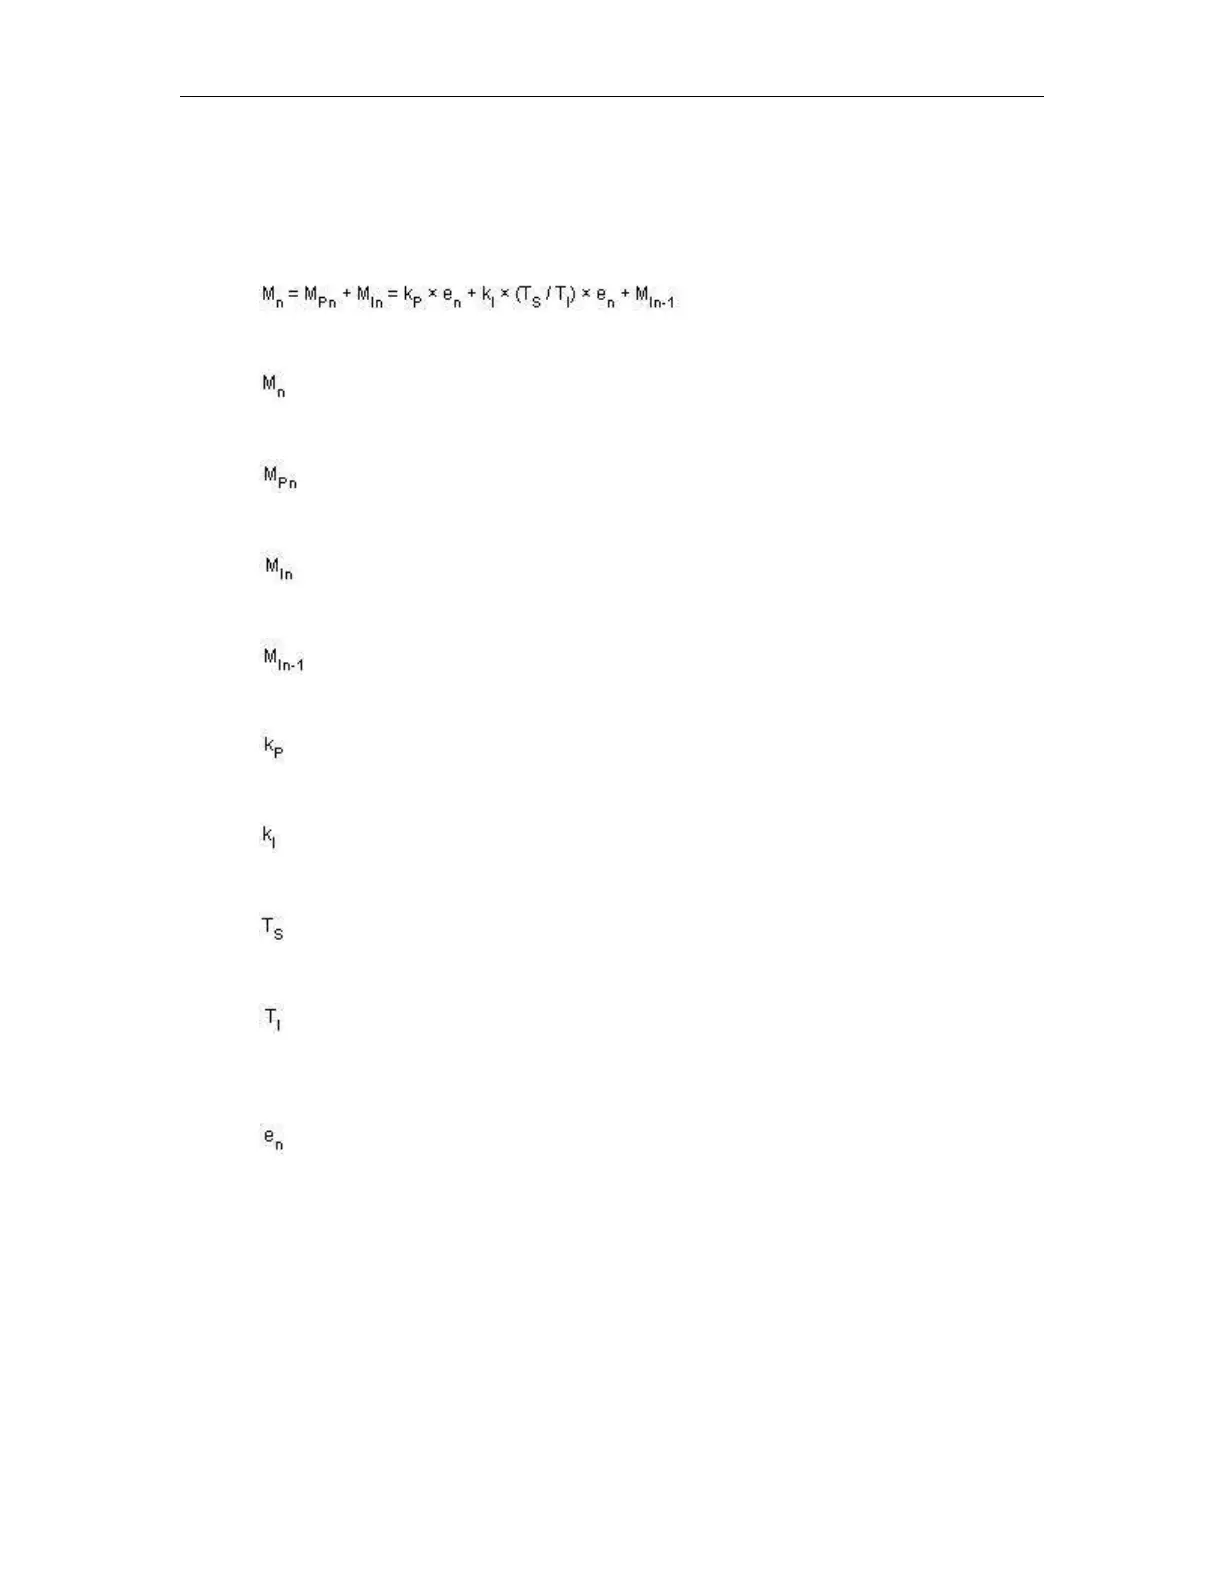
A PI controller reduces the loop error immediately and will eventually drive the loop error to zero.
: Manipulated variable at the time n
: Proportional part of the manipulated variable
: Integral part of the manipulated variable
: Manipulated variable of the I controller at the time n-1; also called integral sum
: Gain of the P controller
: Gain of the I controller
: Sampling time, duration of a time slice
: Integral time; by means of this time the influence of the integral part is controlled on
the manipulated variable, also known as the integral-action time
: Loop error at the time n
The following picture shows a jump in process value and step response of the controller:


 To Next Page