Summary
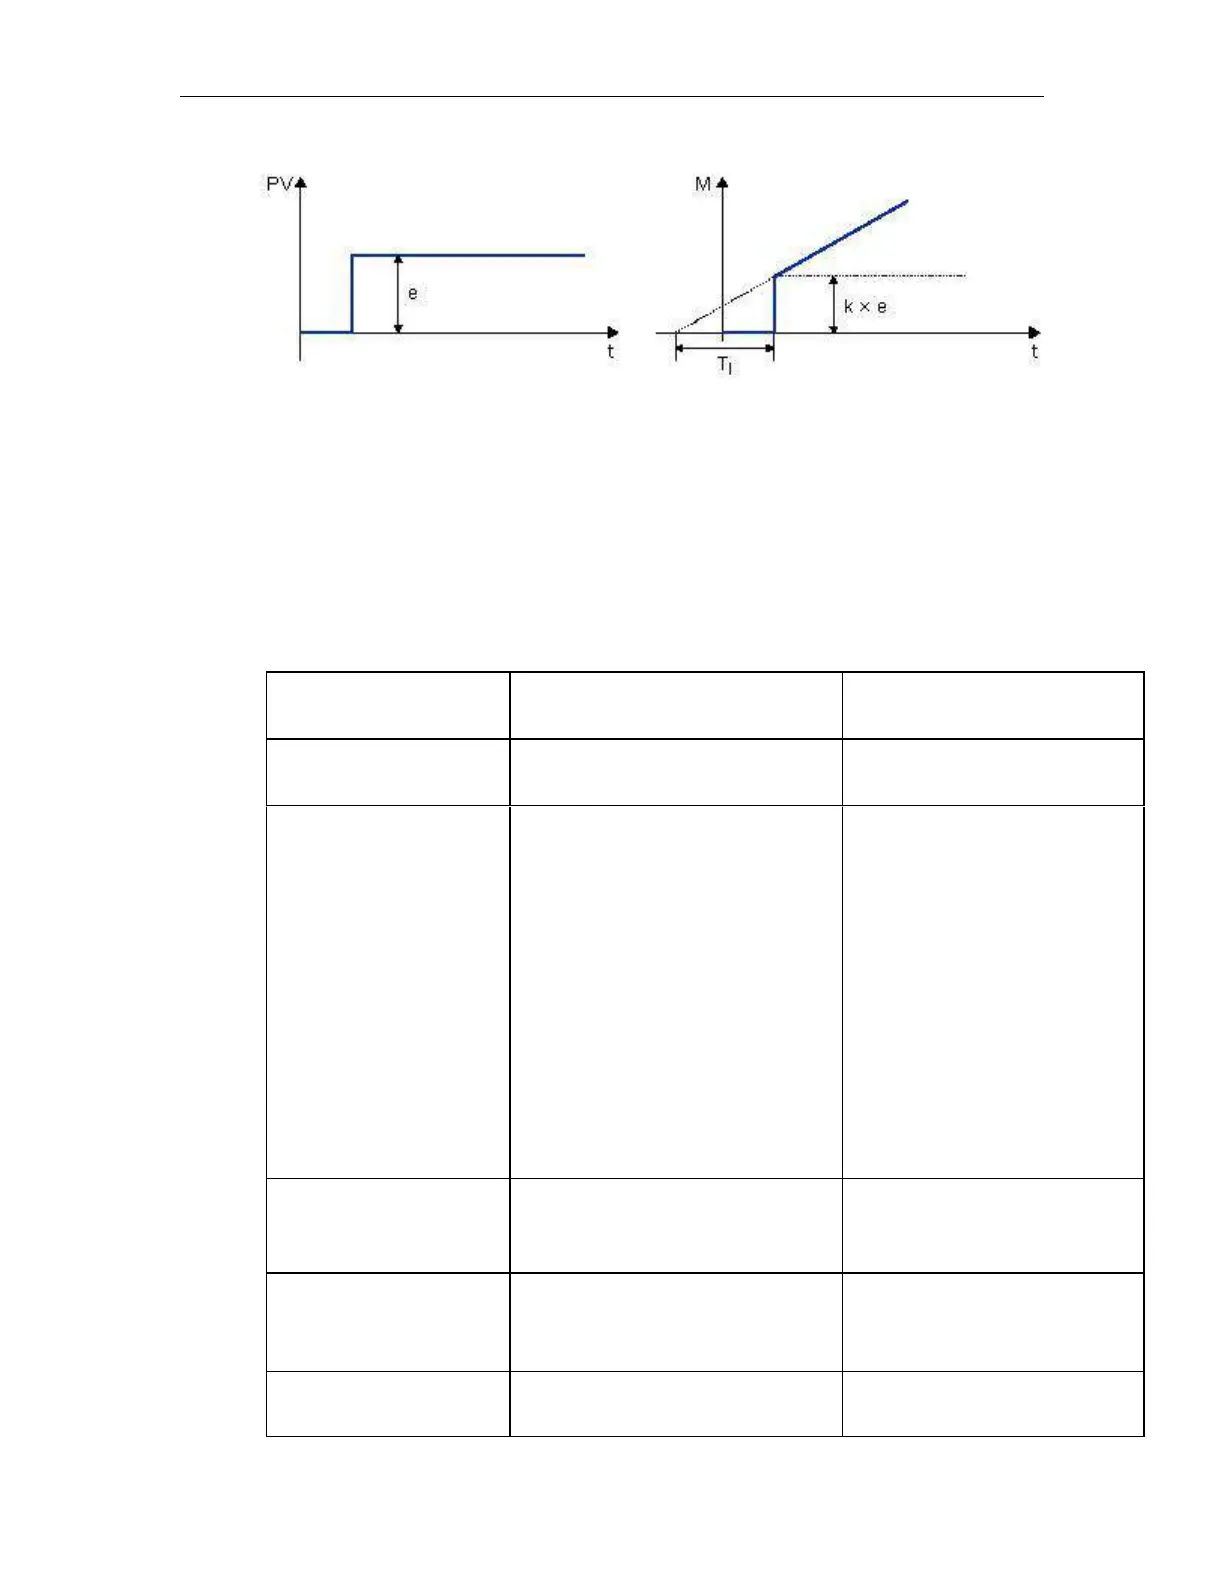
The PI controller has the following characteristics:
The P controller components quickly intercept an occurring loop error.
The I controller components can then remedy the remaining loop error.
The controller components supplement each other so that the PI controller works quickly and precisely.
Description of the individual parameters
Possible value range in the
x-Messenger
Mn Manipulated variable
at the time n
Output of the PI controller block
kP
Gain of the P part
kI
Gain of the I part
In the x-Messenger, the parameter
KC applies as an increase for the I
part and the P part of the controller
equally.
Should you enter KC=0, then the P
part of the controller switches off. In
this special case, k is automatically
set to 1 for the I part. If KC = 0: kP =
0 and kI = 1
If KC <> 0: kP = kI = KC
Ts Sampling time,
duration of a time slice
Parameter TI, if you set this
parameter to 99:59 min, then you
switch off the I part of the controller.


 To Next Page