EasyManua.ls Logo

WEG CFW-09 - Page 129

WEG CFW-09
362 pages
Print Icon
To Next Page IconTo Next Page
To Previous Page IconTo Previous Page
Loading...
130
CHAPTER 6 - DETAILED PARAMETER DESCRIPTION
P138
-10.0 to +10.0 %
Slip Compensation
[ 0.0 ]
0.1 %
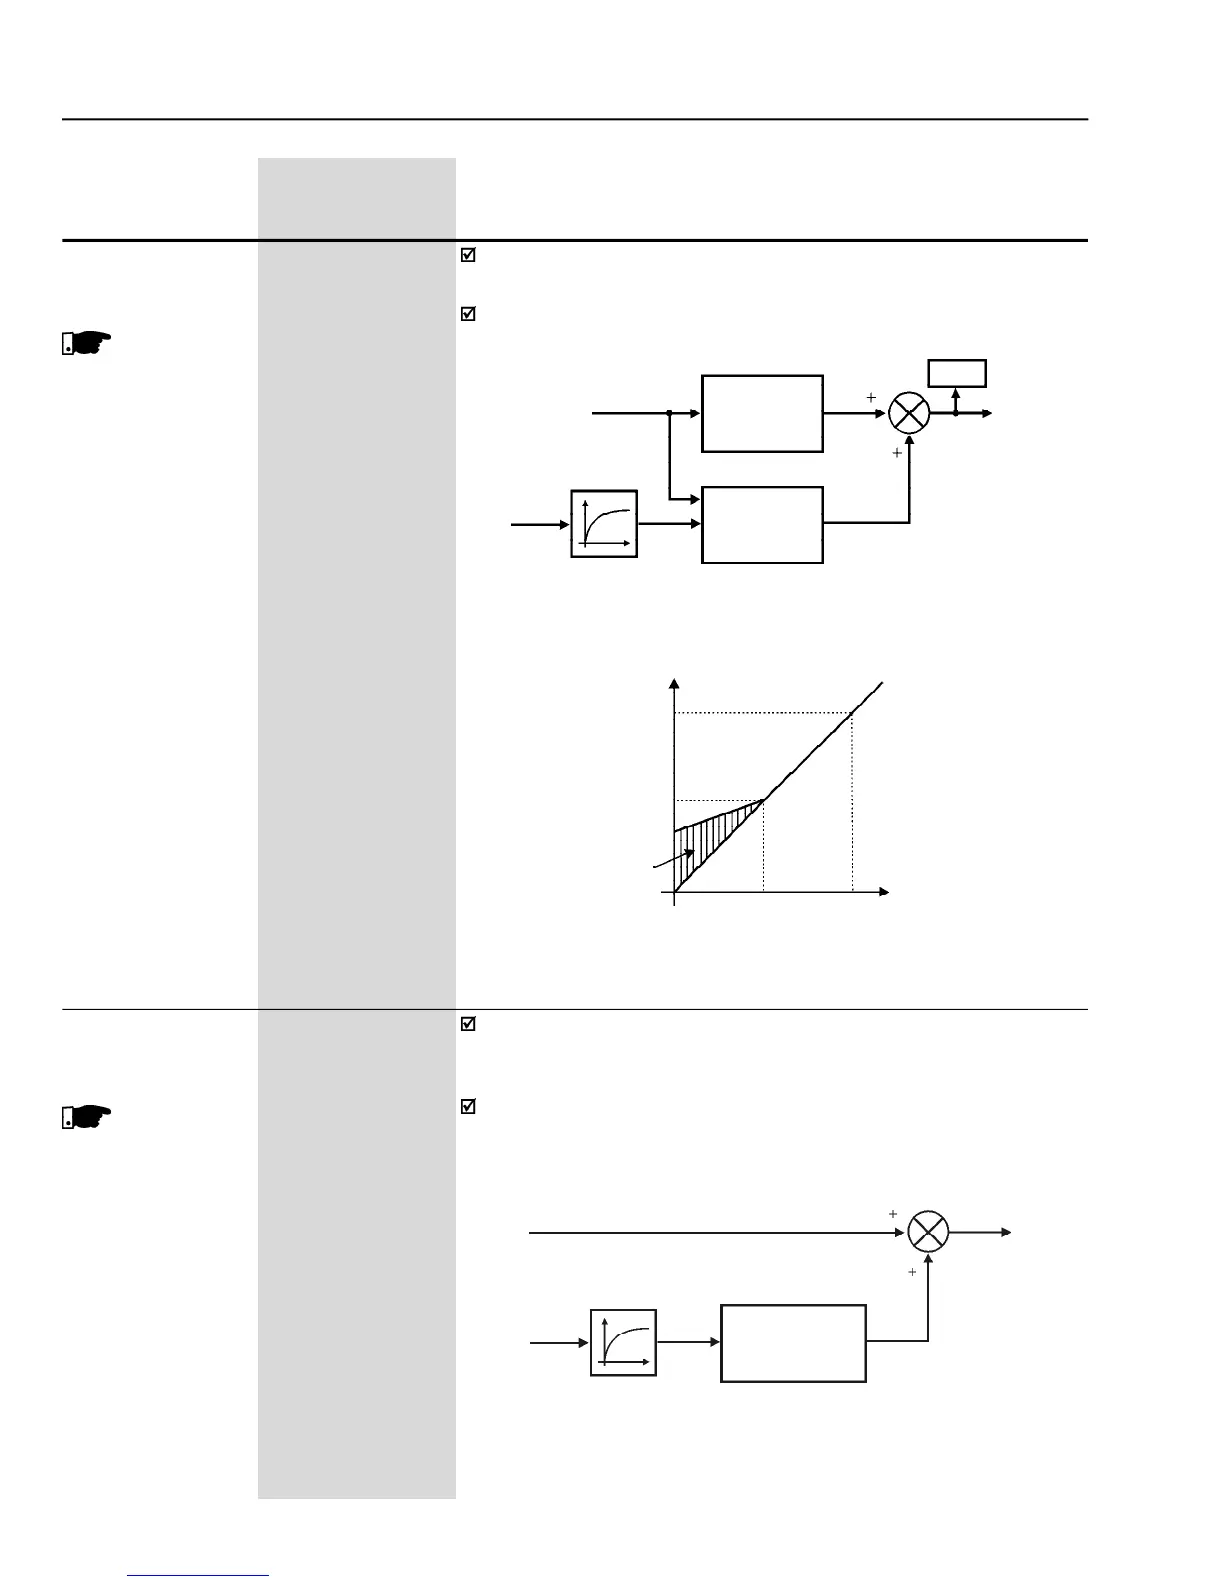
P138 (for values between 0.0 % and +10.0 %) is used in the Motor Slip
Compensation output frequency function, which compensates for the
speed drop as the load increases.
P138allowsthe usertosettheVSDformoreaccurateslipcompensation.
Once set up P138 will compensate for speed variations due to load by
automaticallyadjusting both voltage and frequency.
Figure 6.6
- Block diagram P137
P139
P007
Speed
Reference
Motor
Voltage
Torque Boost
P136
Speed
Nominal
1/2Nominal
Boost
Zone
1/2Nom
Nominal
Figure 6.7
- V/F curve with automatic torque boost
Output Voltage
Automatic
Torque Boost
P137
Output
Active
Current
Range
[Factory Setting]
Parameter
Unit
Description / Notes
Figure 6.8
- Block diagram P138
This parameter
is shown on the
display(s)onlywhen
P202 = 0, 1 or 2
(V/F Control)
P137
0.00 to 1.00
AutomaticTorque
[ 0.00 ]
Boost
0.01
The automatic Torque Boost compensates for the voltage drop in the
stator resistance as a function of the motor active current.
The criteria for setting P137 are the same as for the parameter P136.
This parame-
ter is shown on the
display(s)onlywhen
P202 = 0, 1 or 2
(V/F Control)
Total Reference
(Refer to figures 6.26 and 6.27b))
Speed
Active
Output
Current
P139
P138
Slip
Compensation
F

Table of Contents