CHAPTER 6 - DETAILED PARAMETER DESCRIPTION
This parameter adjusts the DC voltage (DC braking torque) applied to
the motor during the braking process.
The current level set at this parameter represents a percentage of the
This parameter works only for the Sensorless Vector Control.
It is used in functions of the digital and relay outputs: F > Fx.
The DC braking at start consists of applying a DC current to the motor
betweenthe “Start” command and the motor acceleration.
This parameter adjusts the DC braking time at start for the VVW and
Sensorless Vector Control Modes.
If the inverter is disabled during the DC braking operation, the braking
process will continue until the braking time set at P371 finishes. After
that the inverter returns to the “RDY” state.
The DC braking at start is not available for:
The V/Hz and Vector with Encoder Control Modes;
Start commandsthroughtheserialandFieldbusinterfaceswithP202=3;
When the Flying Start function is set (P320
The DC current level is set at P302 (VVW) and P372 (sensorless).
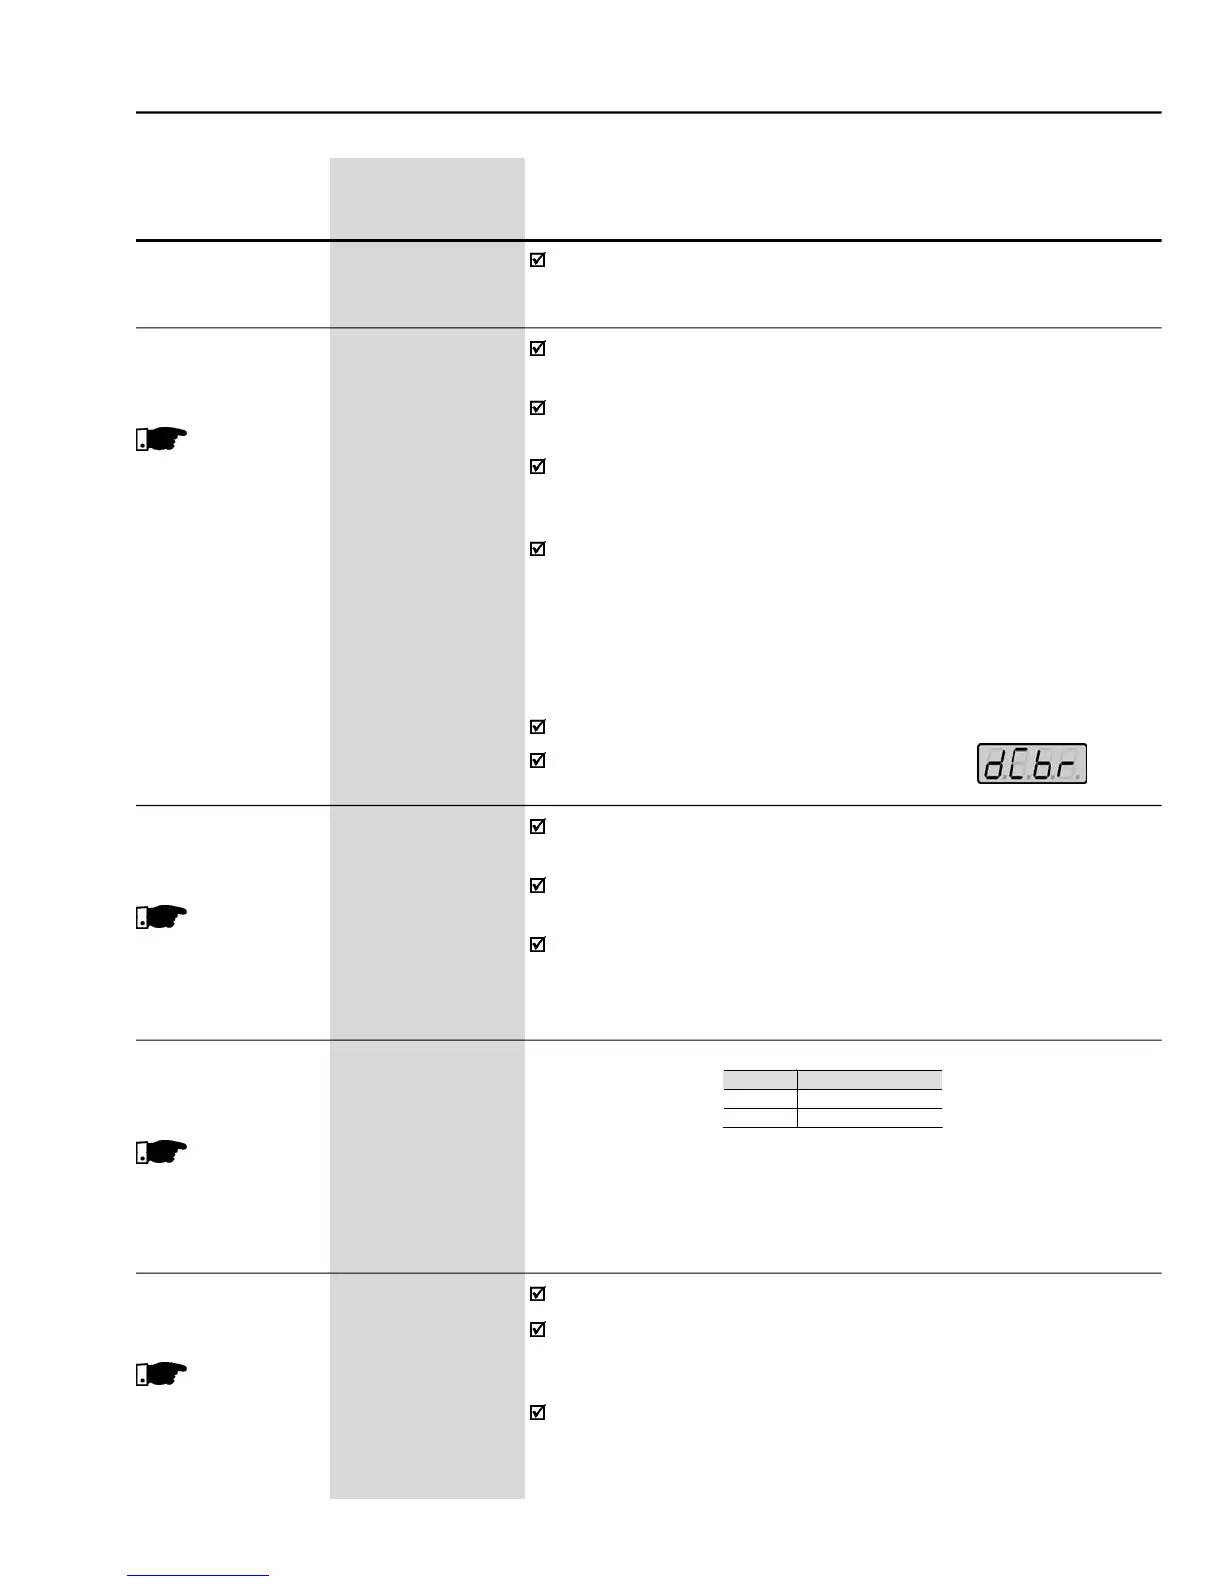
During the DC Braking the LED displays flashes
Slip compensation during regeneration
This parameter sets the motor rated efficiency;
Thisparameter is important to the correctoperation of the VVW Control.
The incorrect settingof this parameter results in the incorrectcalculation
of the slip compensation;
The default value of this parameter is automaticallyset whenparameter
P404 is modified. The suggested value is valid onlyfor IV pole standard
three-phase WEG motors. The user shall set this parameter manually


 To Next Page