6. Diagnostics and optimization
6−67
Festo P.BE−SPC200−WIN−PISA−CD−EN en 0901d
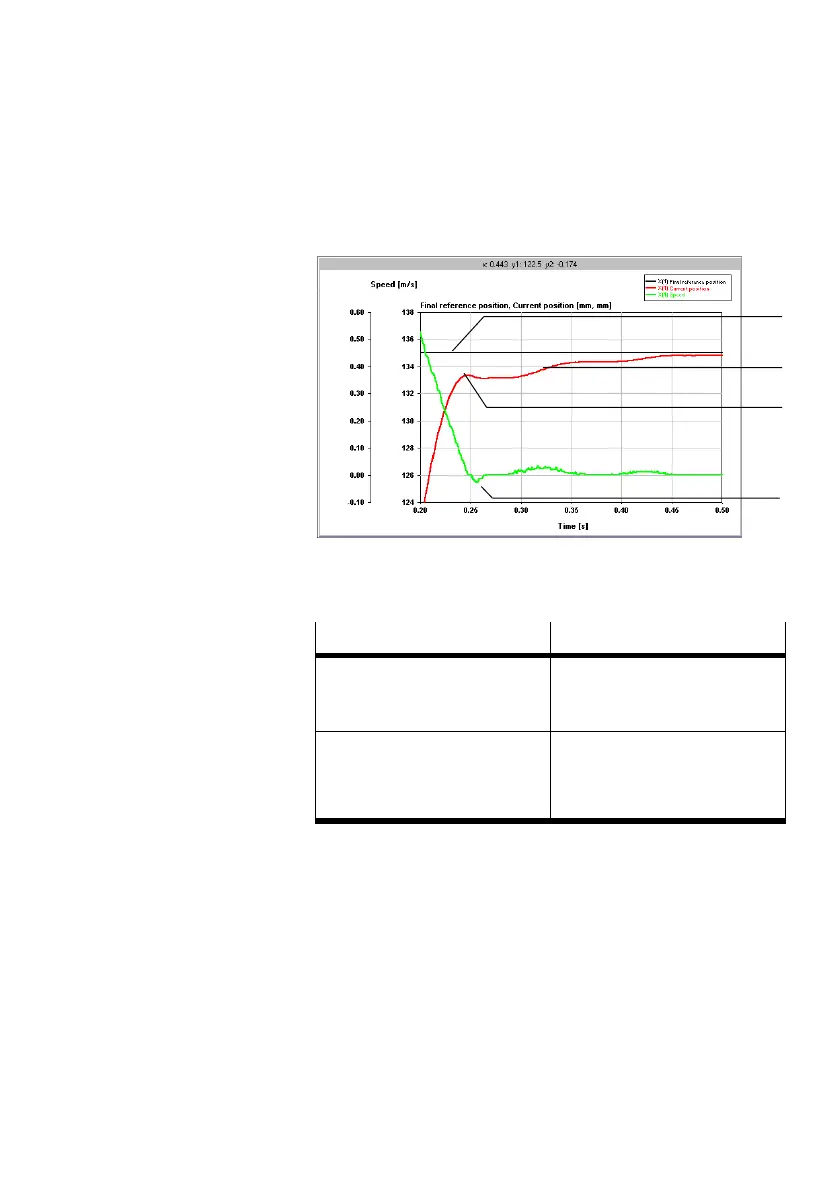
Underswing (no or minimum standing time before MC)
1 Final reference
position
2 Current position
3 Underswing
(sign change of
the speed before
final reference
position is
reached)
4 Speed change
1
2
3
4
Fig.6/33: Underswing
Causes
Remedy
Mass load entered too high
(under circumstances causes
over−cushioned controller)
· Reduce mass load (see sys
tem manual for the SPC200)
Demand too high (fast"
reference values too high)
· Adapt reference values, if
necessary, carry out dynamic
identification (automatic
limitation)




 To Next Page