Chapter 6 FBD Block Diagram Programming 189
PID (Proportion- Integral- Differential) function block
There is a maximum of 30 PI (PID) function blocks under FBD mode, and the function is same as Ladder mode.
PID computes formula:
( )
(
)
∑
∆=
−−=
+
+−=∆
−=
−
−
−
PIPI
PVPVPV
T
T
D
D
EV
T
T
EVEVKPI
PVSVEV
n
nn
S
D
n
n
n
I
s
nnP
nn
2
1
1
2
Parameters can be constant or other function current value. The output coil will turn ON when either T
S
or K
P
is 0.
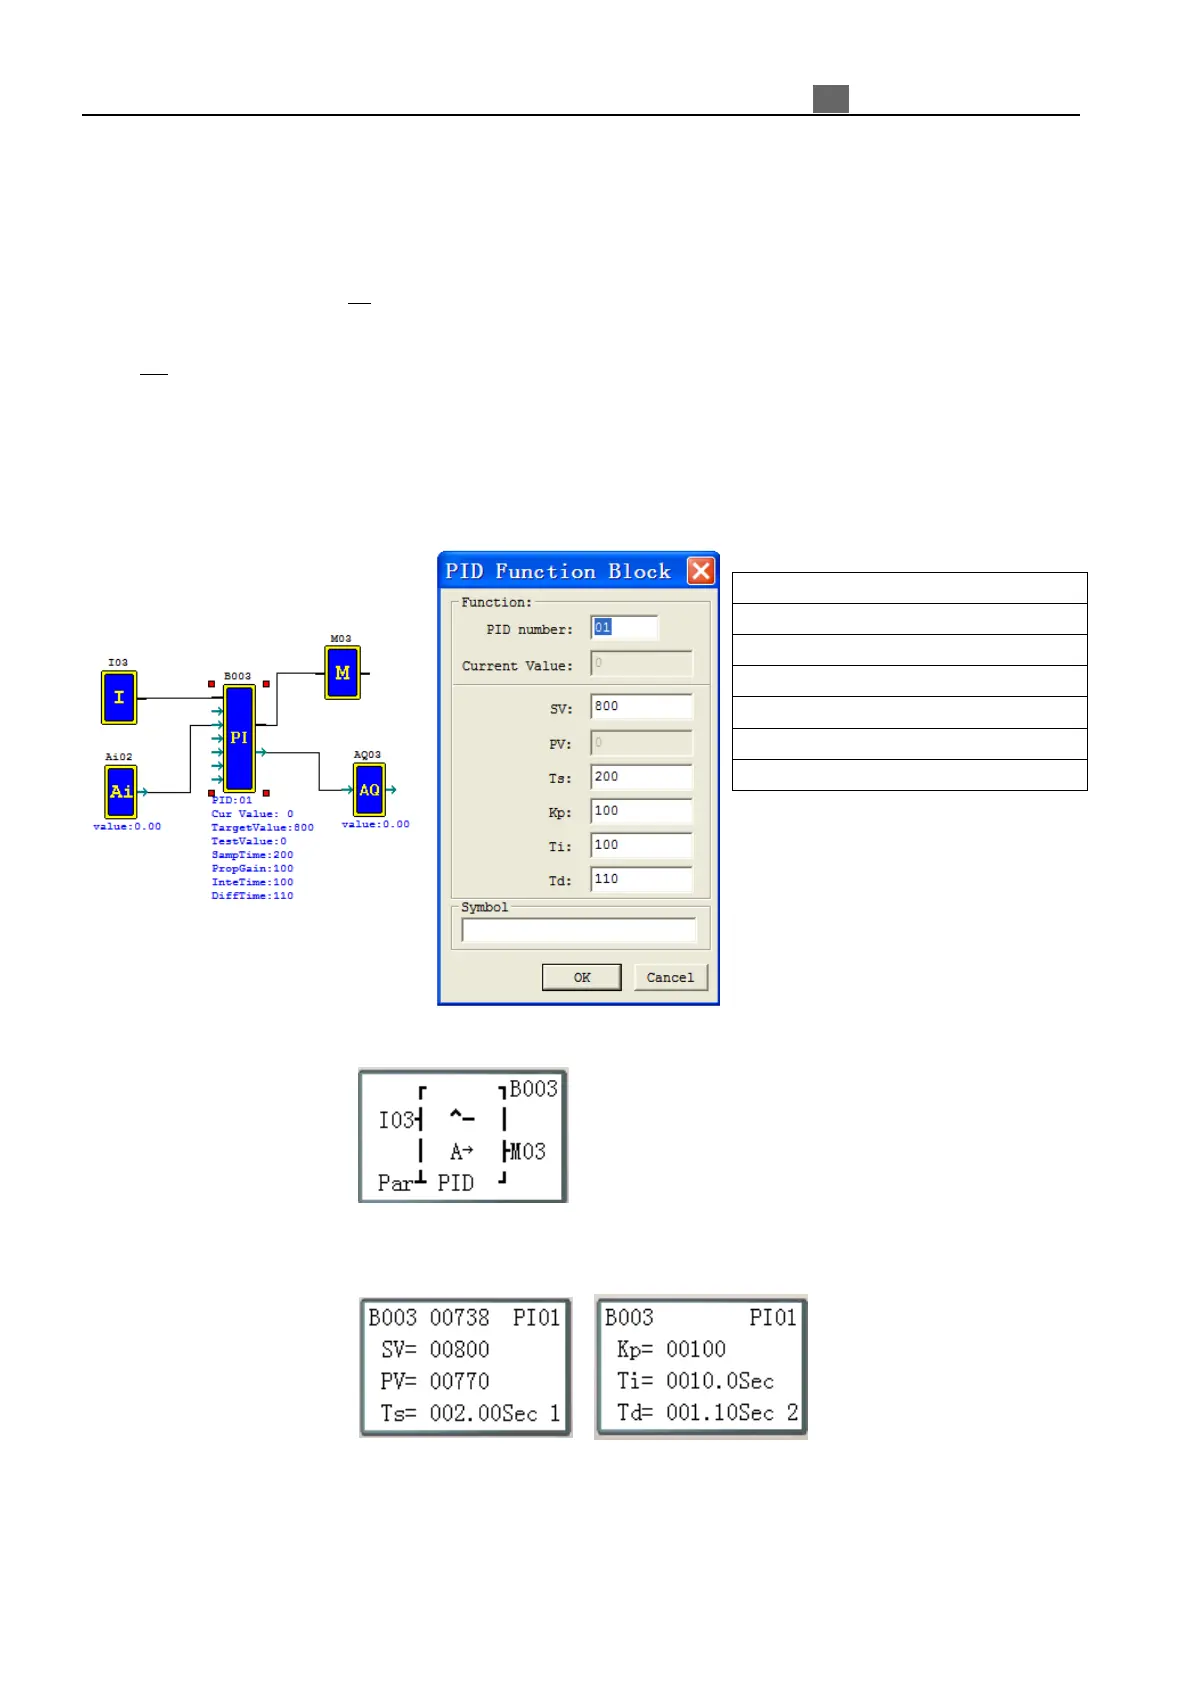
Example:
FBD display:
Parameter display:
※ Display PID current value when running mode;
※ Test value (PV) display code A02 when stopping mode and display current value (as example PV= 00770)
when running mode.
※ Press “SEL+←→” button can convert between display1 and display2.
※ More information about PID function to see Chapter 4: Relay Ladder Logic Programming—PID.
PI: PID current value (-32768~32767)
SV: Destination value (-32768~32767)
PV: Test value (-32768~32767)
S
: Sampling time (1~32767 * 0.01s)
P
: Proportional gain (1~32767 %)
I
: Integration time (1~32767 * 0.1s)
D
: Differential time (1~32767 * 0.01s)


 To Next Page