F.4
SEL-749M Relay Instruction Manual Date Code 20080918
Motor Thermal Element
The Basic Thermal Element
To define a thermal element for an induction motor, the characteristics of each
component in Figure F.2 must be defined, starting with the heat source. In an
induction motor, heat principally is caused by I
2
r losses. To consider the
effects of negative-sequence current (I
2
) on the motor, the heat source is called
out separately in Equation F.1.
Equation F.1
Heating factors K
1
and K
2
are defined by the positive-sequence rotor
resistance and negative-sequence rotor resistance, respectively.
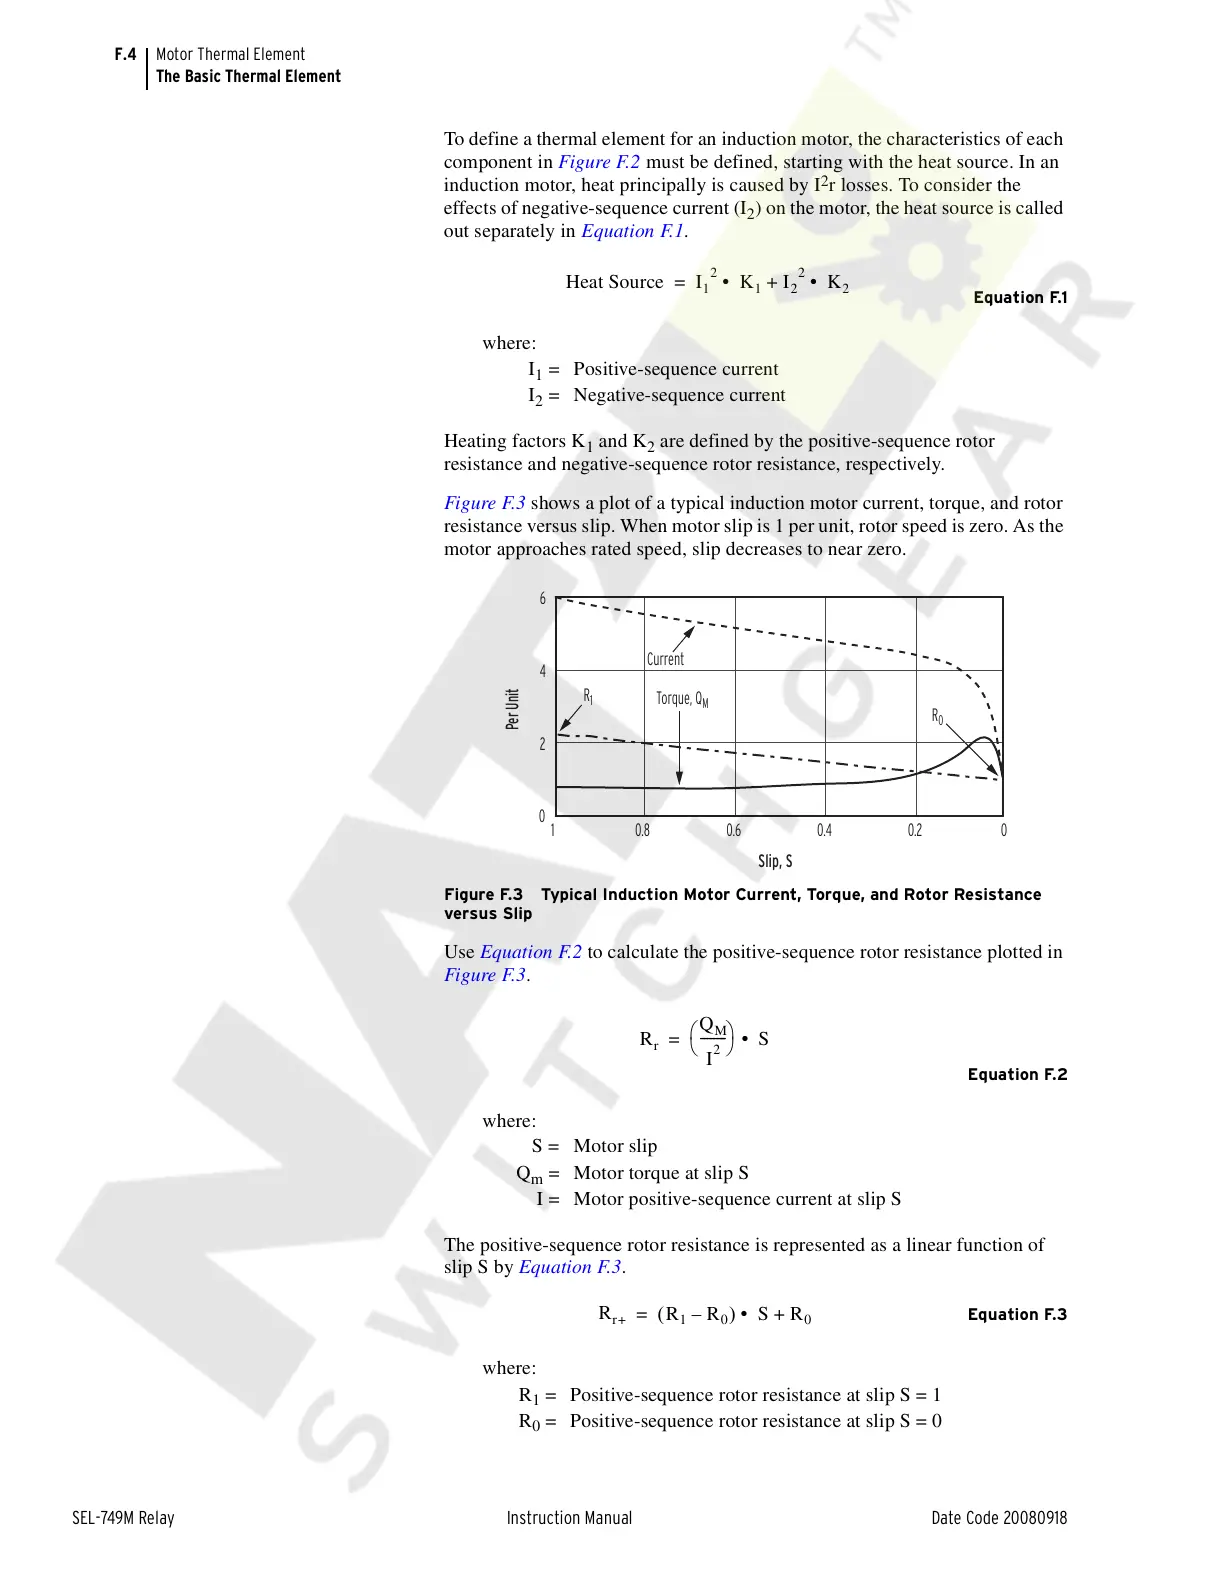
Figure F.3 shows a plot of a typical induction motor current, torque, and rotor
resistance versus slip. When motor slip is 1 per unit, rotor speed is zero. As the
motor approaches rated speed, slip decreases to near zero.
Figure F.3 Typical Induction Motor Current, Torque, and Rotor Resistance
versus Slip
Use Equation F.2 to calculate the positive-sequence rotor resistance plotted in
Figure F.3.
Equation F.2
The positive-sequence rotor resistance is represented as a linear function of
slip S by Equation F.3.
Equation F.3
where:
I
1
= Positive-sequence current
I
2
= Negative-sequence current
where:
S = Motor slip
Q
m
= Motor torque at slip S
I = Motor positive-sequence current at slip S
where:
R
1
= Positive-sequence rotor resistance at slip S = 1
R
0
= Positive-sequence rotor resistance at slip S = 0
Heat Source I
1
2
K
1
• I
2
2
K
2
• +=
1 0.8 0.6 0.4 0.2
0
2
4
6
Slip, S
0
Current
Torque, Q
M
R
1
R
0
Per Unit
R
r
Q
M
I
2
--------
⎝⎠
⎛⎞
S• =
R
r+
R
1
R
0
–()SR
0
+• =
Courtesy of NationalSwitchgear.com



 To Next Page