CHAPTER 6 - DETAILED PARAMETER DESCRIPTION
Torque generated bythe motor in normal operation, driven by an
inverter in “motor mode”.
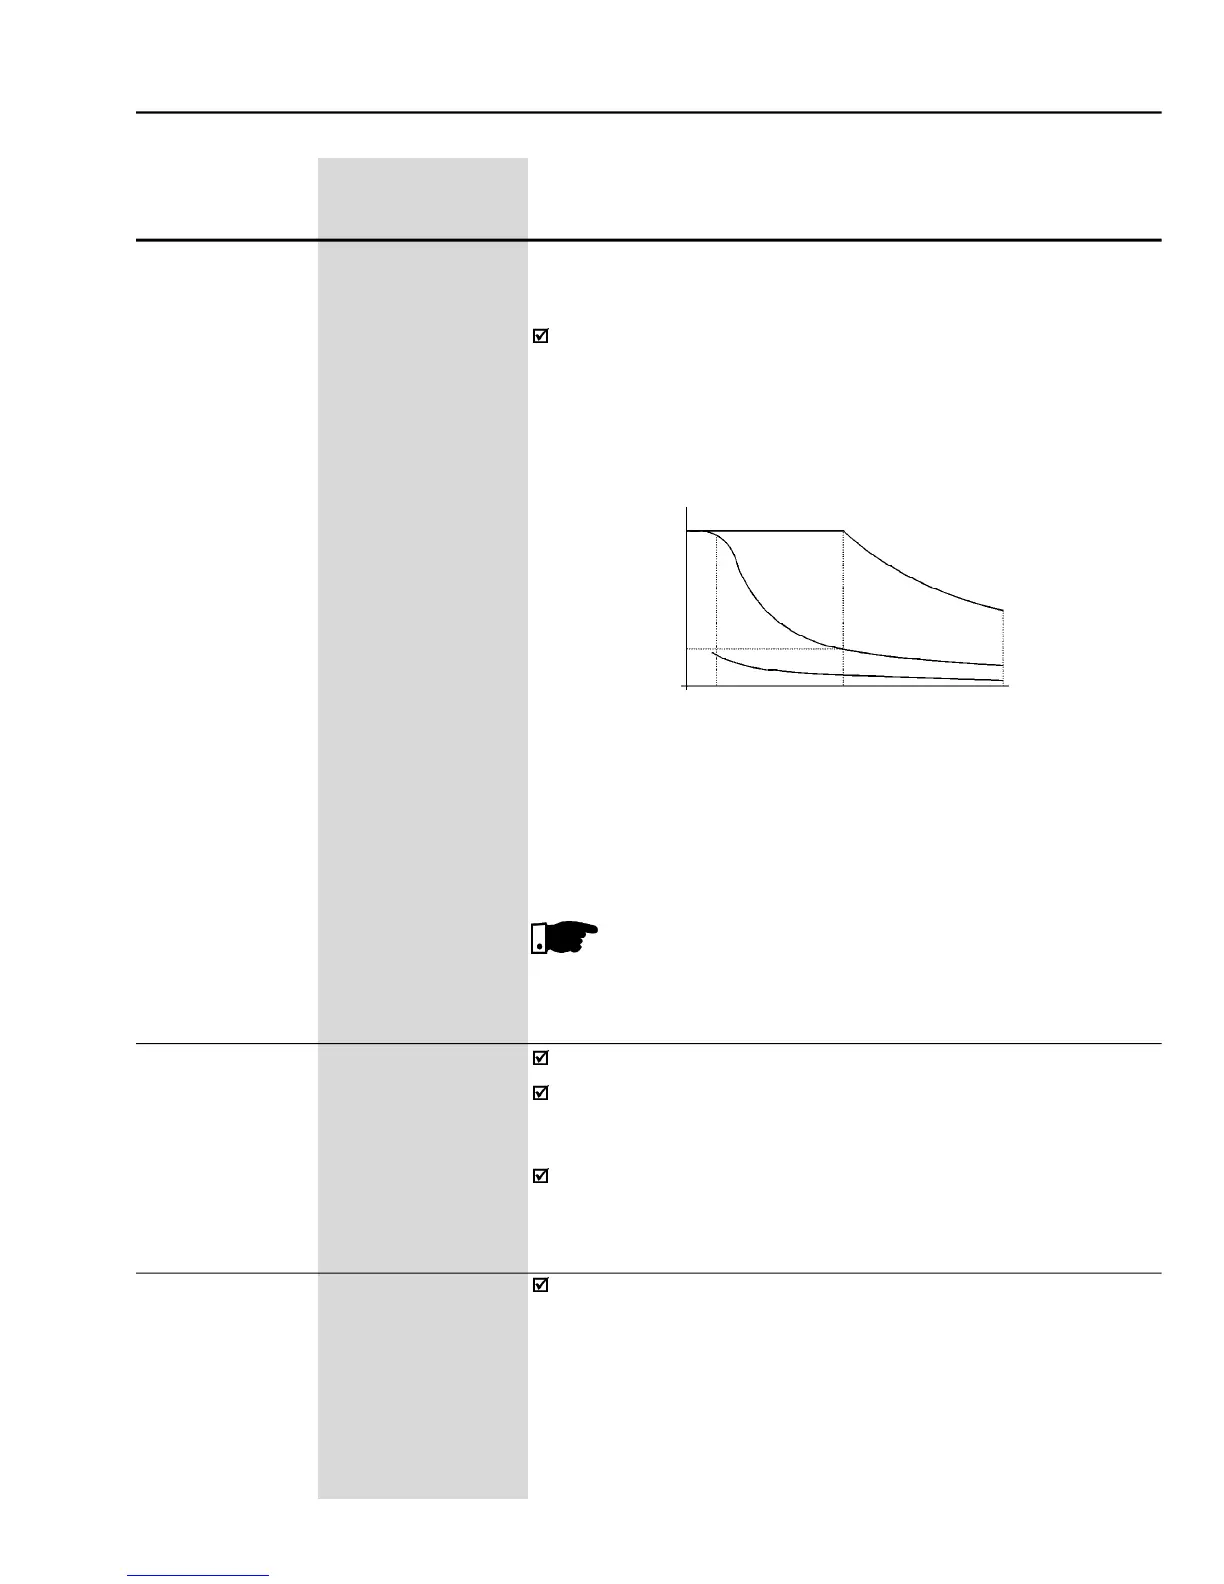
Braking torque generated by Optimal Braking
Braking torque generated with DC Injection Braking
Theenabling of the optimal brakingcan increase the motornoise
level and the vibration level. If this
- T x rpm curve for optimal braking and typical 10 hp/7.5 kW motor
driven by an inverter with torque limitation set for a value equal to the rated motor
Refer to P151 for V/F Control (figure 6.14).
If P152 = 0.00 and P151 is different from the maximum value, the
Ramp Holding function is active. (Refer to P151 for the Scalar Control
P152 multiplies the DC Link voltage error, i.e. DC Link actual - DC
Link setting (P151). P152 is typically used to prevent overvoltage in
applications with eccentric loads.
Dynamic braking can only be used if the inverter is fitted with a dynamic
braking resistor. The voltage level for actuation of the brake chopper
must be set according to the supply voltage. If P153 is set too close to
the overvoltage triplevel (E01) an overvoltage trip may occur before the
brakechopperandresistorcandissipate thebrakingenergy.Thefollowing
are the recommended settings:
Thebrakingtorqueindicated infigure 6.15canbeincreasedbyincreasing
the inverter torque limit: P169(maximum forwardtorquecurrent) or P170
(maximum reverse torque current).
In general, smaller motors have lower efficiency (higher losses)
consequentlyOptimal Braking can achieve higher braking torques with
Examples: 0.75 kW/1 hp, IV poles:
= 0.76 that results in TB1 = 0.32
= 0.86 that results in TB1 = 0.16


 To Next Page