EasyManua.ls Logo

WEG CFW-09 - Page 142

WEG CFW-09
362 pages
Print Icon
To Next Page IconTo Next Page
To Previous Page IconTo Previous Page
Loading...
143
CHAPTER 6 - DETAILED PARAMETER DESCRIPTION
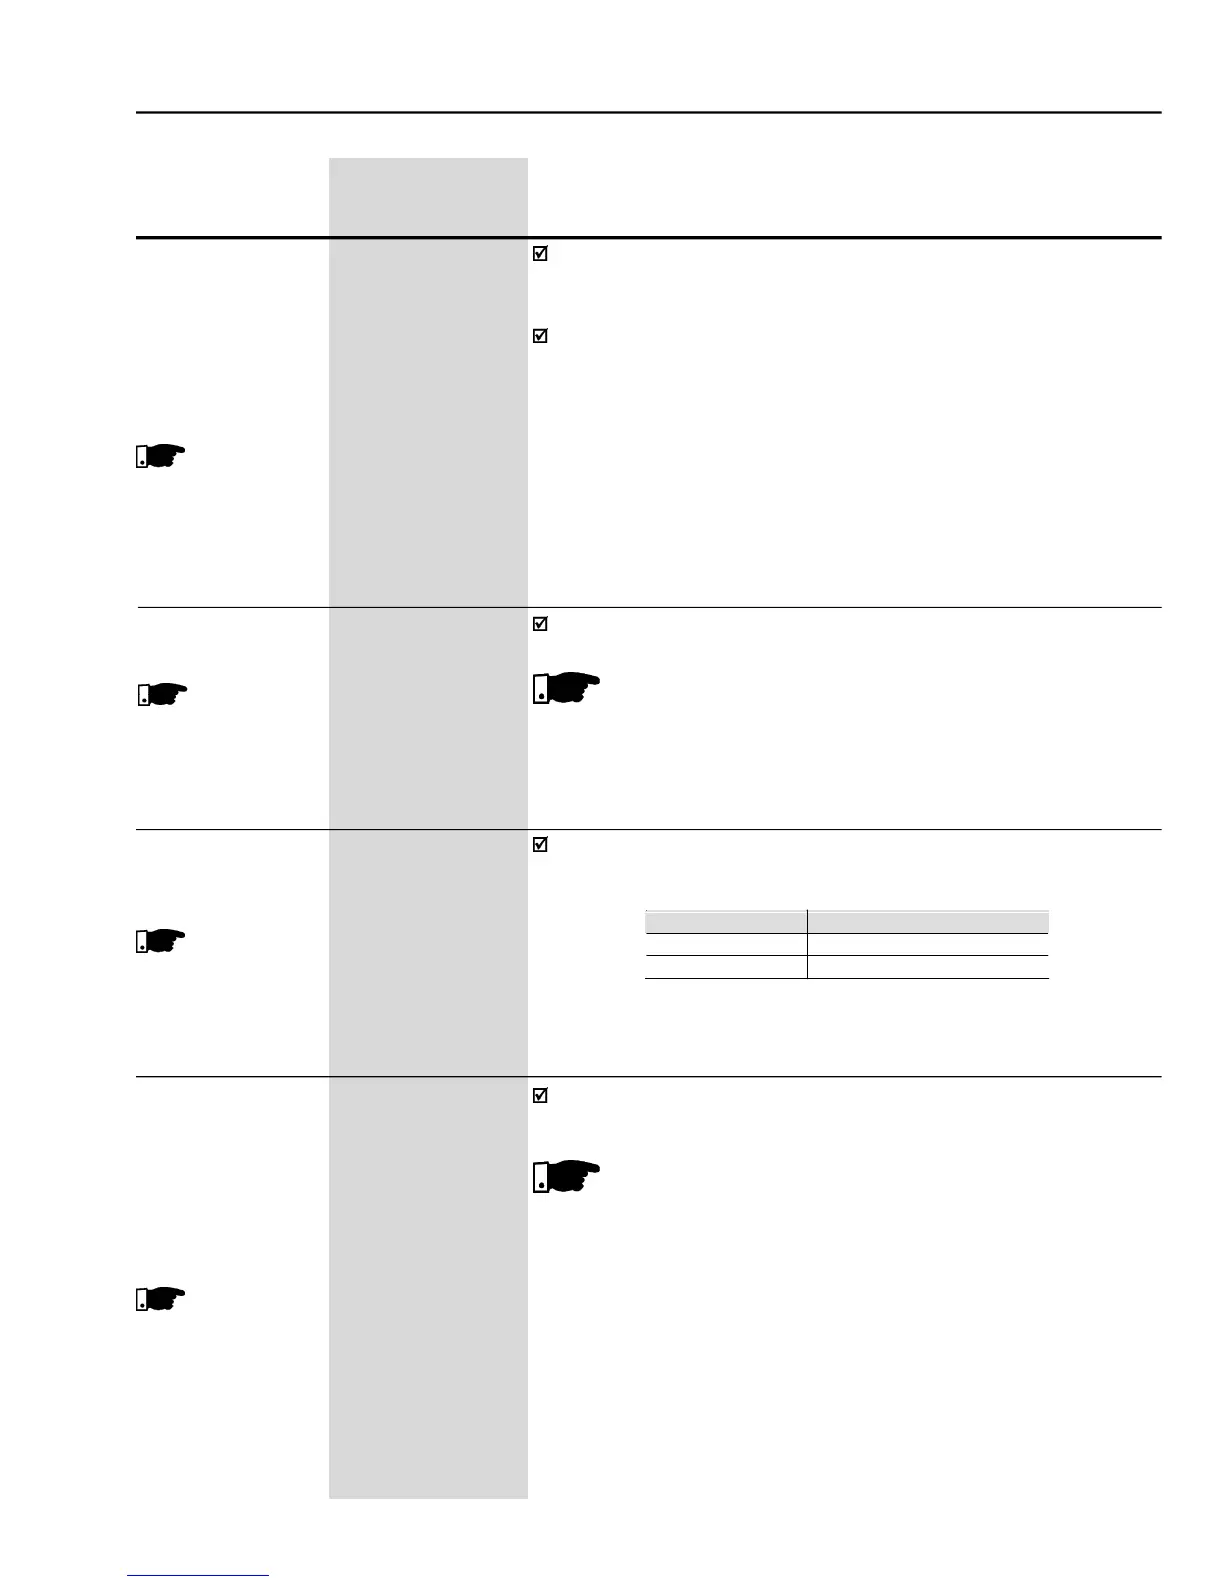
P167
(4)
0.00 to 1.99
ProportionalGain of
[ 0.5 ]
the Current Regulator
0.01
P168
(4)
0.000 to 1.999
Integral Gain of the
[0.010 ]
CurrentRegulator
0.001
NOTE!
These parameters must not be changed.
Range
[Factory Setting]
Parameter
Unit
Description / Notes
Parameters
(P166 and P167 and
P168) are shown
on the display(s)
only when
P202 = 3
or 4 (Vector
Control)
P166
0.00 to 7.99
Speed Regulator
[ 0.00 ]
Differential Gain
-
Thedifferential actionmayreducethe effectsonthemotor speedcaused
by the load variation. Refer to figure 6.27 a).
This para-
meter is shown on
the
display(s)only
when
P202 = 3 or 4
(VectorControl)
P163
-999 to 999
LocalSpeed
[ 0 ]
ReferenceOffset
1
P164
-999 to 999
RemoteSpeed
[ 0 ]
ReferenceOffset
1
Parameters P163 or P164 may be used to compensate a bias offset at
theanaloginputsignals,whenthespeedreferenceisgivenbythe analog
inputs (AI1 to AI4).
Refer to figure6.26.
These para-
meters(P160 toP164)
are shown on the
display(s)onlywhen
P202 = 3 or 4 (Vector
Control)
P165
0.012 to 1.000
Speed Filter
[ 0.012 ]
0.001 s
This para-
meter is shown on
the
display(s)only
when
P202 = 3 or 4
(VectorControl)
Adjusts the time constant for the Speed Filter. Refer to figure 6.27 a).
NOTE!
In general, this parameter shall not be changed. Increasing the
speed filter value renders the system response slower.
P166
Differential Gain
A
ction
0
.
0
Off
0
.
01
to
7
.
99
On
The parameters P167 and P168 are set by the self-tuning routine as a
function of parameters P411 and P409, respectively.
Table 6.10
- Speed regulator differential gain action

Table of Contents