Def / Type
FbEq 16b / 32b
DescriptionName / Range /
Selection
No.
- / real32Maximum torque reference for speed controller adaptation.
Speed controller gain can be adapted according to the final
unlimited torque reference (26.1 Torque reference to TC).
This can be used to smooth out disturbances caused by
a small load and backlashes.
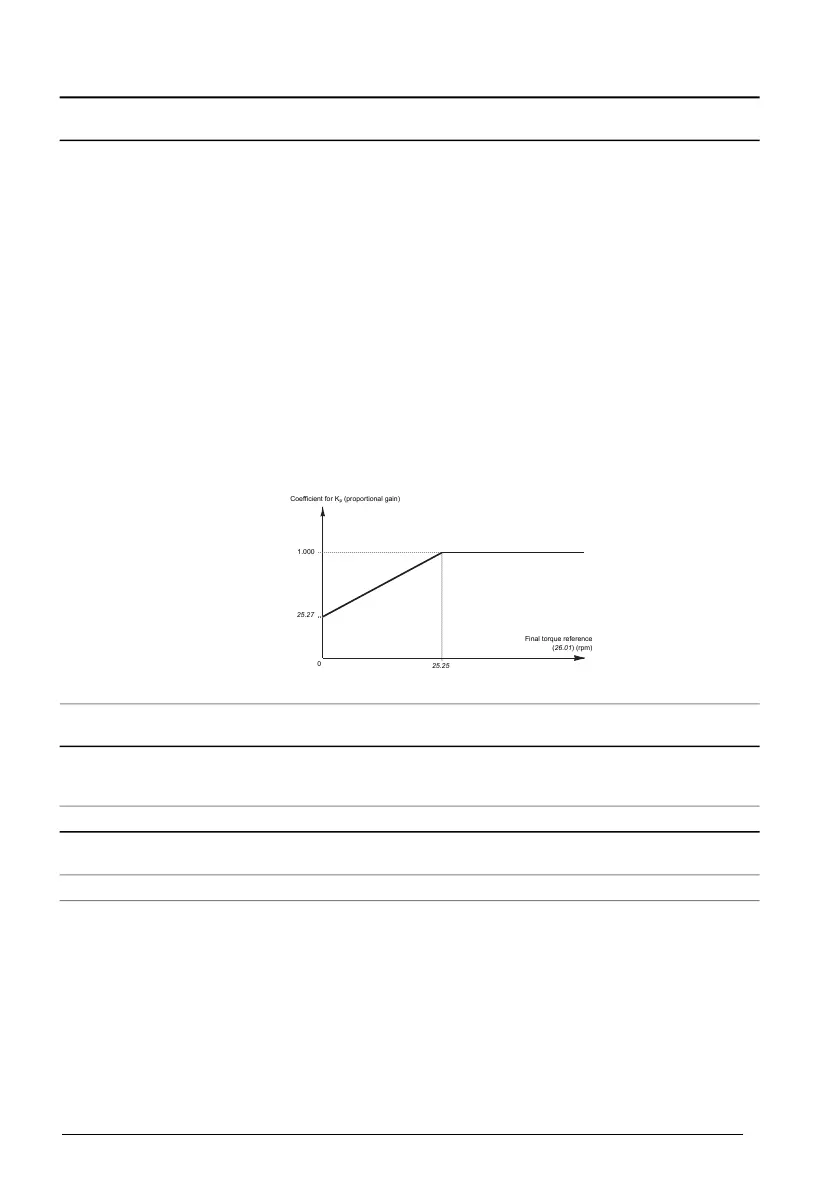
The functionality involves multiplying the gain (25.2 Speed
proportional gain) by a coefficient within a certain torque
range.
When the torque reference is 0%, the gain is multiplied by
the value of parameter 25.27 Kp adapt coef at min torque.
When the torque reference is equal to or above 25.25
Torque adapt max limit, no adaptation takes place (the
coefficient is 1).
Between 0% and 25.25 Torque adapt max limit, the
coefficient for the gain is calculated linearly on the basis
of the breakpoints.
Filtering can be applied on the torque reference using
parameter 25.26 Torque adapt filt time.
See also the block diagram on page 630.
1.000
25.27
Coefficient for K
p
(proportional gain)
Final torque reference
(26.01) (rpm)
25.25
0
Torque adapt max
limit
25.25
- / -Maximum torque reference for speed controller adaptation.
For scaling, see parameter 46.3.
0.0 ... 1600.0 %
0.000 s / real32Defines a filter time constant for the adaptation, in effect
adjusting the rate of change of the gain.
See parameter 25.25 Torque adapt max limit.
Torque adapt filt time25.26
100 = 1 s / 1000 = 1 sFilter time for adaptation.0.000 ... 100.000 s
1.000 / real32Proportional gain coefficient at 0% torque reference.
See parameter 25.25 Torque adapt max limit.
Kp adapt coef at min
torque
25.27
1000 = 1 / 1000 = 1Proportional gain coefficient at 0% torque reference.0.000 ... 10.000
292 Parameters


 To Next Page