9
Apollo Motor Overload Protection
The Apollo Control System provides two types of motor overload protection.
•
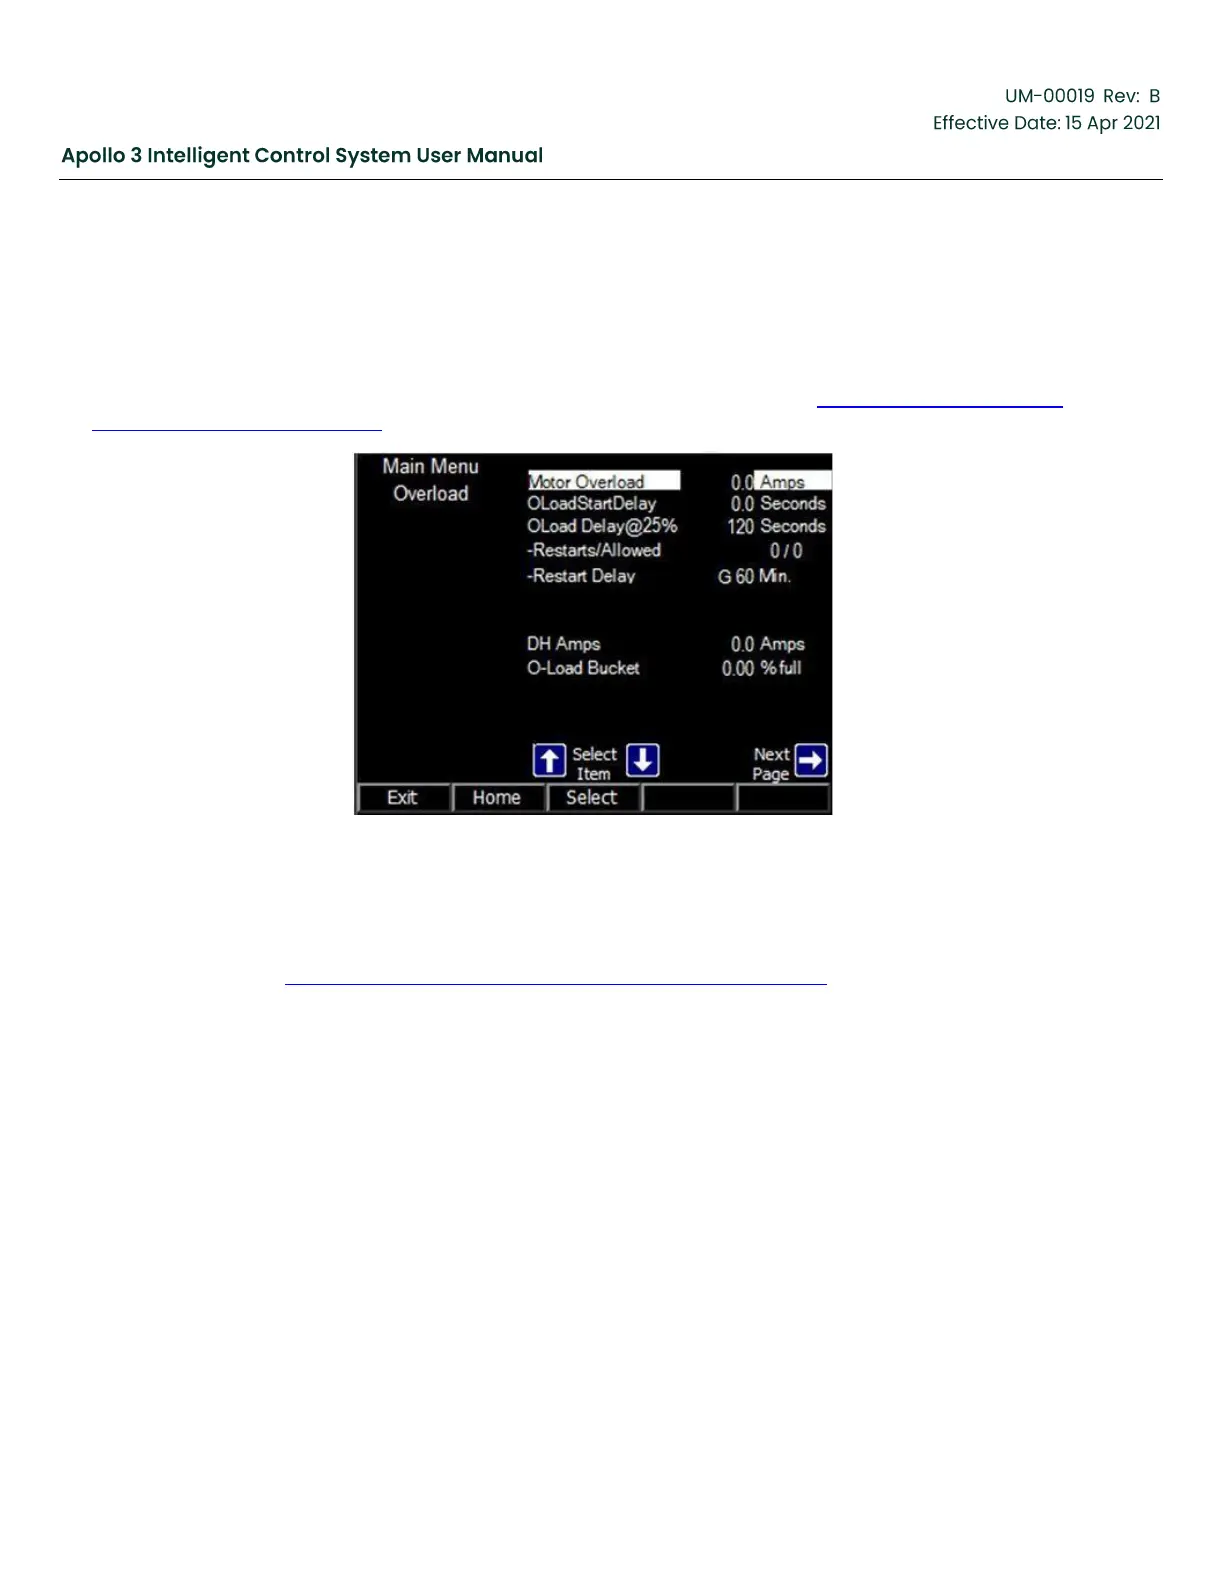
I2T Motor Overload– The I2T overload algorithm protects the motor from heat damage by modeling the heat
buildup in the motor. The parameters for setting up the I2T overload are shown in Figure 191: Motor Overload
Setup Menu-Screen 1, page 220.
Figure 191: Motor Overload Setup Menu-Screen 1
•
Fixed Threshold/Time Delay Overload– The fixed threshold overload algorithm is referred to as Motor
OverCurrent in the Apollo system and protects the motor from heat damage by monitoring motor current using a
simple thresholding algorithm. The parameters for setting up the overcurrent protection are accessible by selecting
Motor OverCurrent in Figure 192: Motor Overload Setup Menu–Screen 2, page 221.


 To Next Page