19. Navigation Sensors
19-2
ARPA:
If checked, ARPA is used as speed and course source. The following indications appear to denote source:
(bottom): Log operating in bottom tracking mode.
(water): Log operating in water tracking mode.
(posit.): Position receiver such as GPS.
(manual): Manual speed.
Manual heading:
If chosen, the operator enters heading manually. Note that this is used only if there are no other sensors chosen.
Gyro1:
Heading source is a gyrocompass. "(mag)" means the source is magnetic heading. True heading source has no
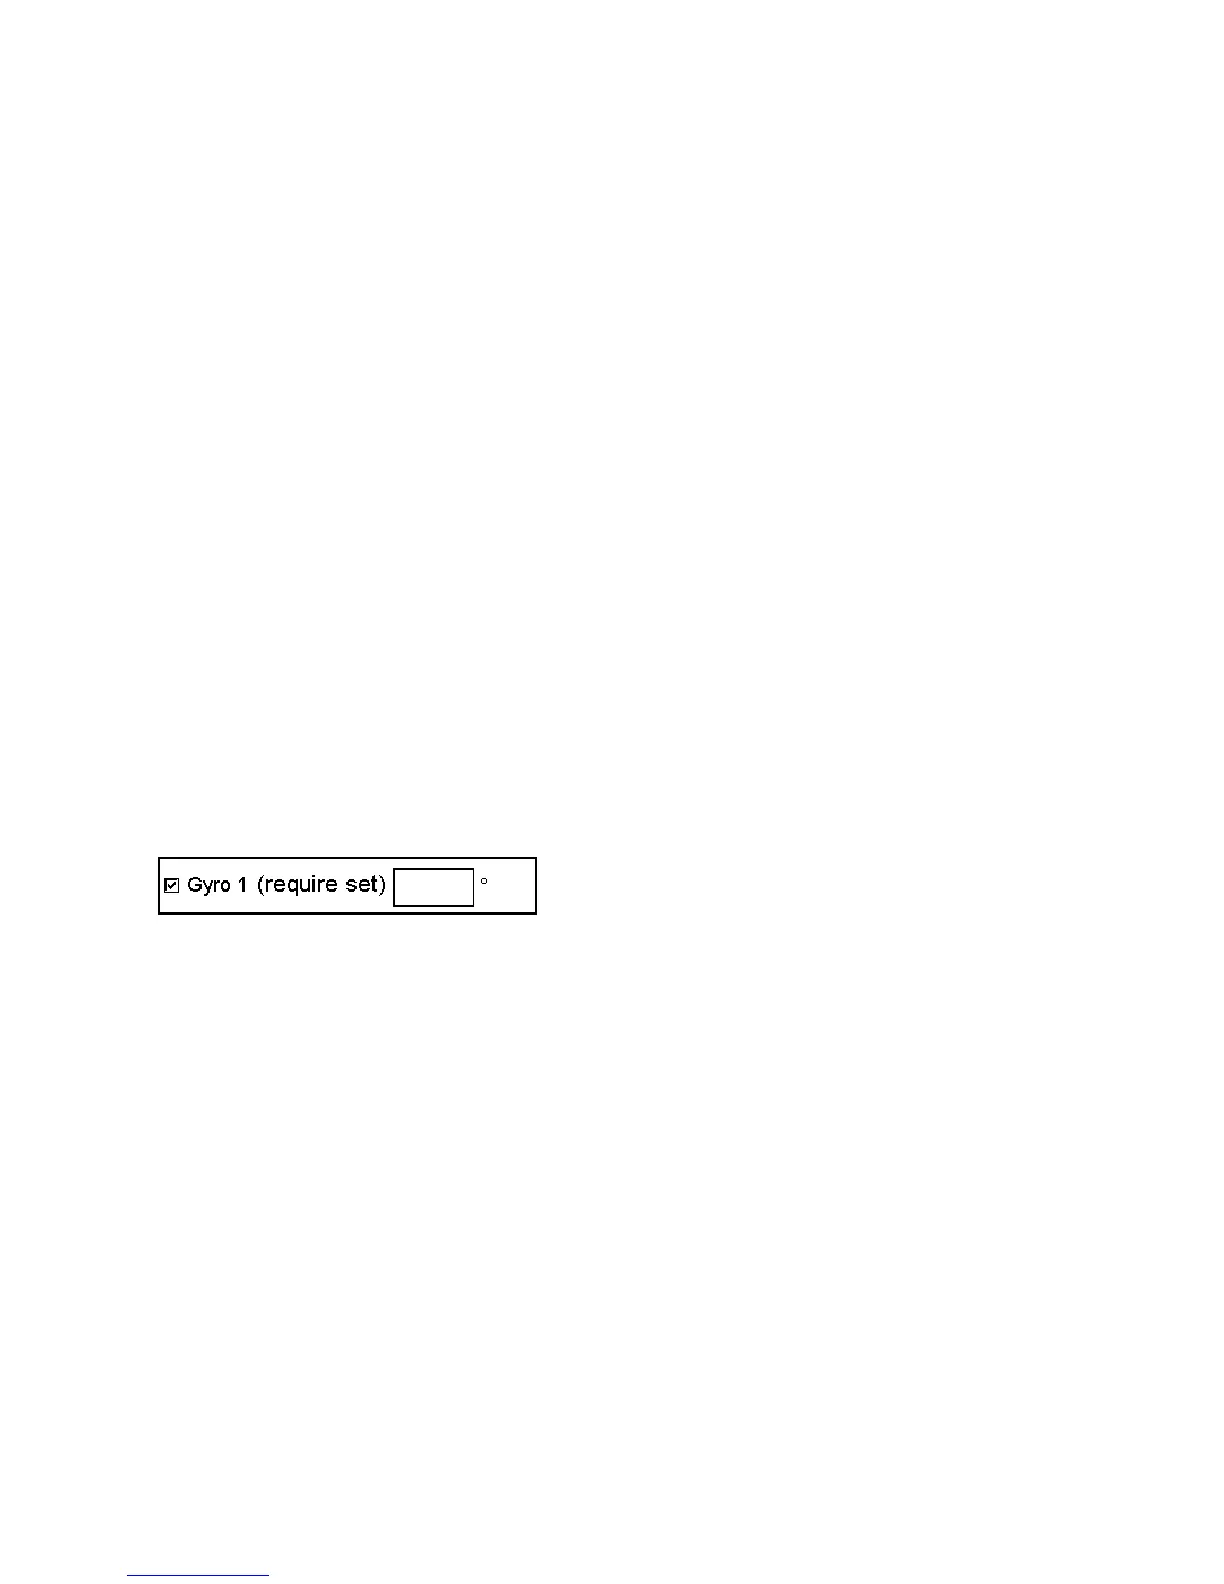
indication. If the source of Gyro1 is a gyro with synchro or stepper interface, the indication "(require set)" appears
when you need to set a new initial value for the gyro.
Gyro2:
Heading source is a gyrocompass. "(mag)" means the source is magnetic heading. True heading source has no
indication.
If you have both gyro1 and gyro2 chosen and if their value differs more than 5°, the system generates the alarm
"2004 Gyro data unreliable".
Rate gyro:
Heading source is a Rate of Turn gyro. "(calc.)" means the rate of turn is calculated from gyro movement.
Setting initial value of gyro1:
Initial setting of gyro1 is not necessary if it outputs serial data. However, if it is of synchro or stepper type, you will
need to set initial gyro value. If gyro1 requires initial value, then the indication "(require set)" is displayed. Use the
scrollwheel to enter initial value. After you enter a value "require set" disappears.


 To Next Page