19. Navigation Sensors
19-8
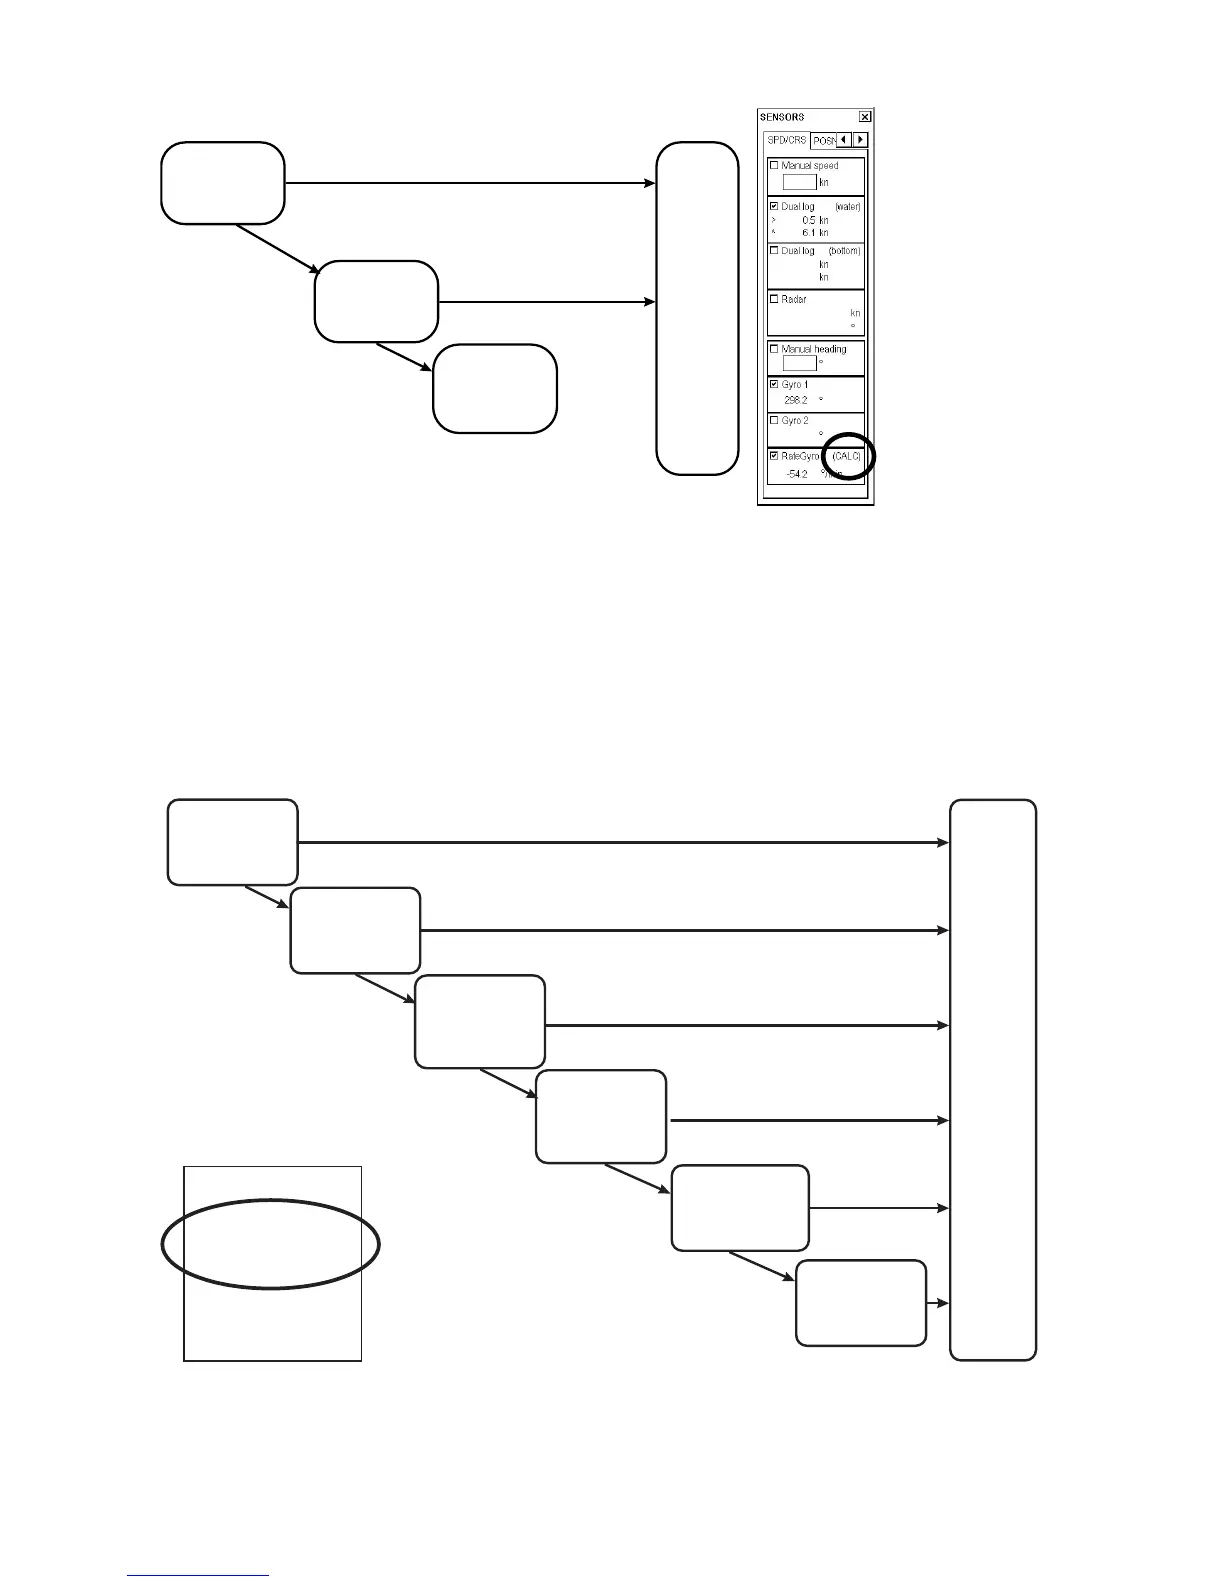
Calculated ROT
from movement
of Heading
Not selected in Installation parameters
Selected in Installation parameters
ROT Gyro
No value
Alarm 718
ROT gyro error
Value exists
ROT
used by
system
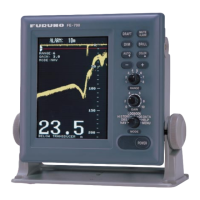
SOG/COG used by the system is shown at the upper right corner of the ECDIS display. In the example below, COG
and SOG are from selected position sensors and this is indicated with the text "(pos)". Other text that denote
SOG/COG source are
(BOT): Bottom tracking dual-axis log
(CALC): Speed calculated from SOG
(WT): Water tracking log
(RDR): Mixed sources of COG and SOG in the connected radar
(POSN): Average of selected position sensors
(FILTER): Kalman filter
(MAN): Manual entry
Note that (pos), (bot), (wat) and (man) could come from direct interfaces of the system or from the connected radar.
DUAL LOG
(Bottom track of
dual-axis doppler
log)
RADAR
(measures
SOG/COG
from target
= Autodrift)
Average of
SOG/COG from all
selected Decca,
Loran or
Ref.Target
KALMAN filter
calculation result
from the movement
of position
SOG/COG
used by
the system
Selected and value existts
SOG/COG from all
Average of
selected DGPS,
GPS or SYLEDIS
Selected and value exists
Selected and value exists
Selected and value exists
Not selected
or no value
Water speed
and
Gyro heading
Selected and
value exists
Not selected
or no value
Not selected
or no value
Not selected
or no value
Not selected
or no value
HDG 071.0
°
SPD (WT) 15.6 kn
SB (POSN) 0.0 kn
COG (POSN) 071.0
°
SOG (POSN) 15.6 kn
59
°
31.206'N
024
°
36.731'E
WGS 84
DGPS


 To Next Page